RP1
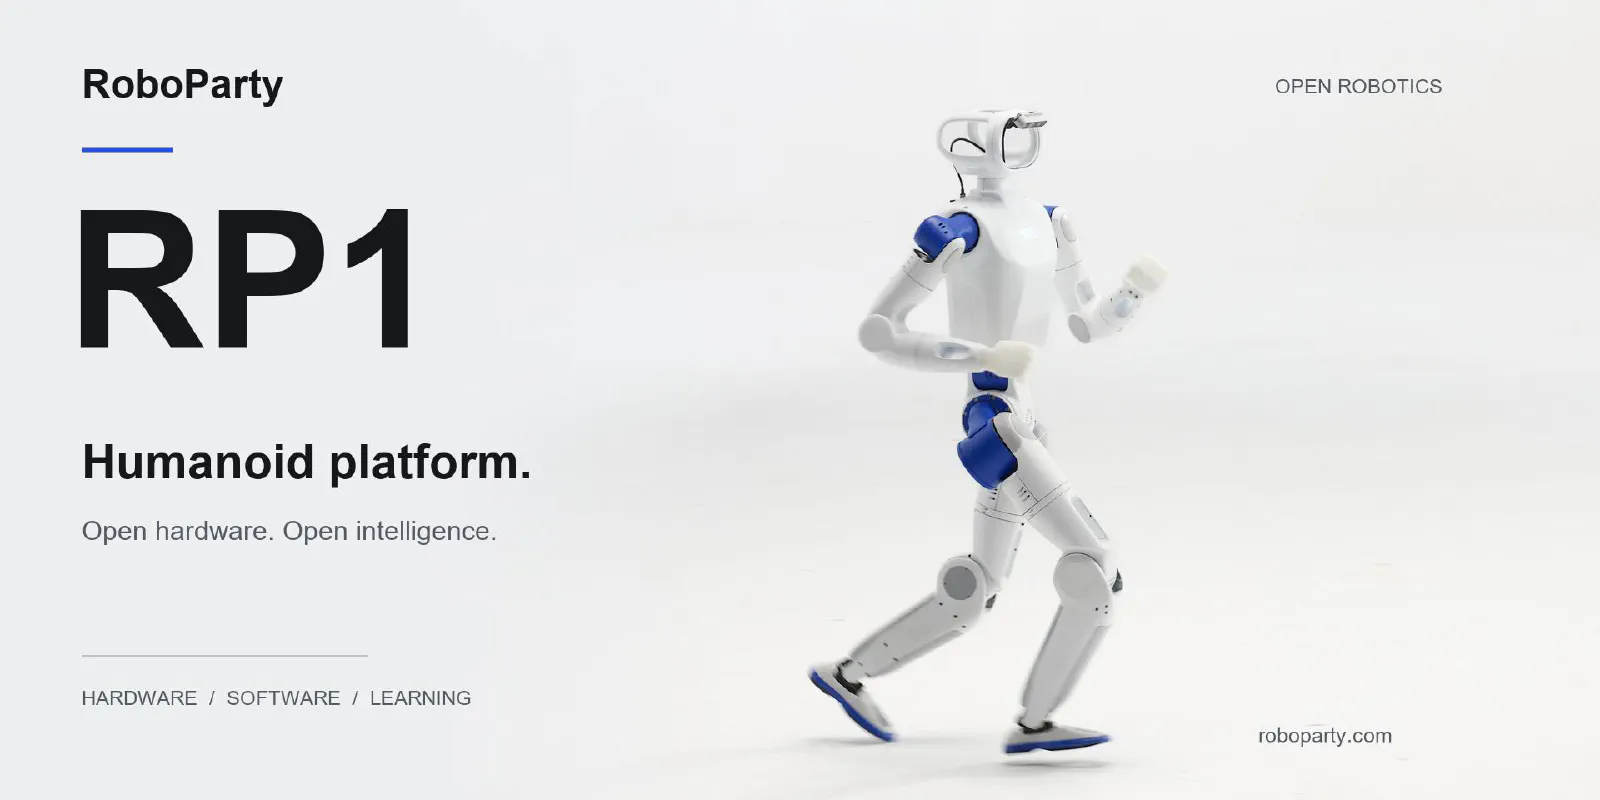
Table of contents
Source repository: Roboparty/RP1
Official product page: RoboParty RP1
License: GPL-3.0
Overview#
RP1 is RoboParty’s open-source full-stack platform for agentic humanoids. It connects mechanical design, electronics, joint modules, firmware, robot models, deployment, and learning in one development stack.
The project is intended to make the complete robot easier to inspect, reproduce, and extend. Developers can work on a single subsystem or build an end-to-end control and learning workflow around the platform.
My Role#
I lead motion control development and serve as the project’s primary open-source maintainer. My responsibilities include:
- Identifying motor parameters and tuning joint modules for control and simulation.
- Exporting and optimizing robot description files for training, simulation, and deployment.
- Building training and simulation environments for developing and validating control policies.
- Developing deployment software and troubleshooting sim-to-real transfer on the physical robot.
Platform Stack#
| Area | Repositories and resources |
|---|---|
| Hardware and tools | rp1_hardware , ROMOMO , RP Hand , RP1_TEST , roboparty_joystick |
| Software and systems | roboparty_deploy , RP1_description , roboparty_train , RP1_firmware |
RP1 supports multiple robot configurations, including 24, 28, 30, and 42 DoF variants. See the description repository for the current release and configuration details.
Learning Projects#
The RoboParty learning stack includes locomotion, motion imitation, tracking, and behavior-model work such as AMP , BeyondMimic , MimicLite , UFO , and PBFM .
Related Project#
Roboto Origin is the earlier RoboParty open-source humanoid robot project documented on this site. RP1 extends that direction into a broader, connected platform covering the full robot stack.
Comments