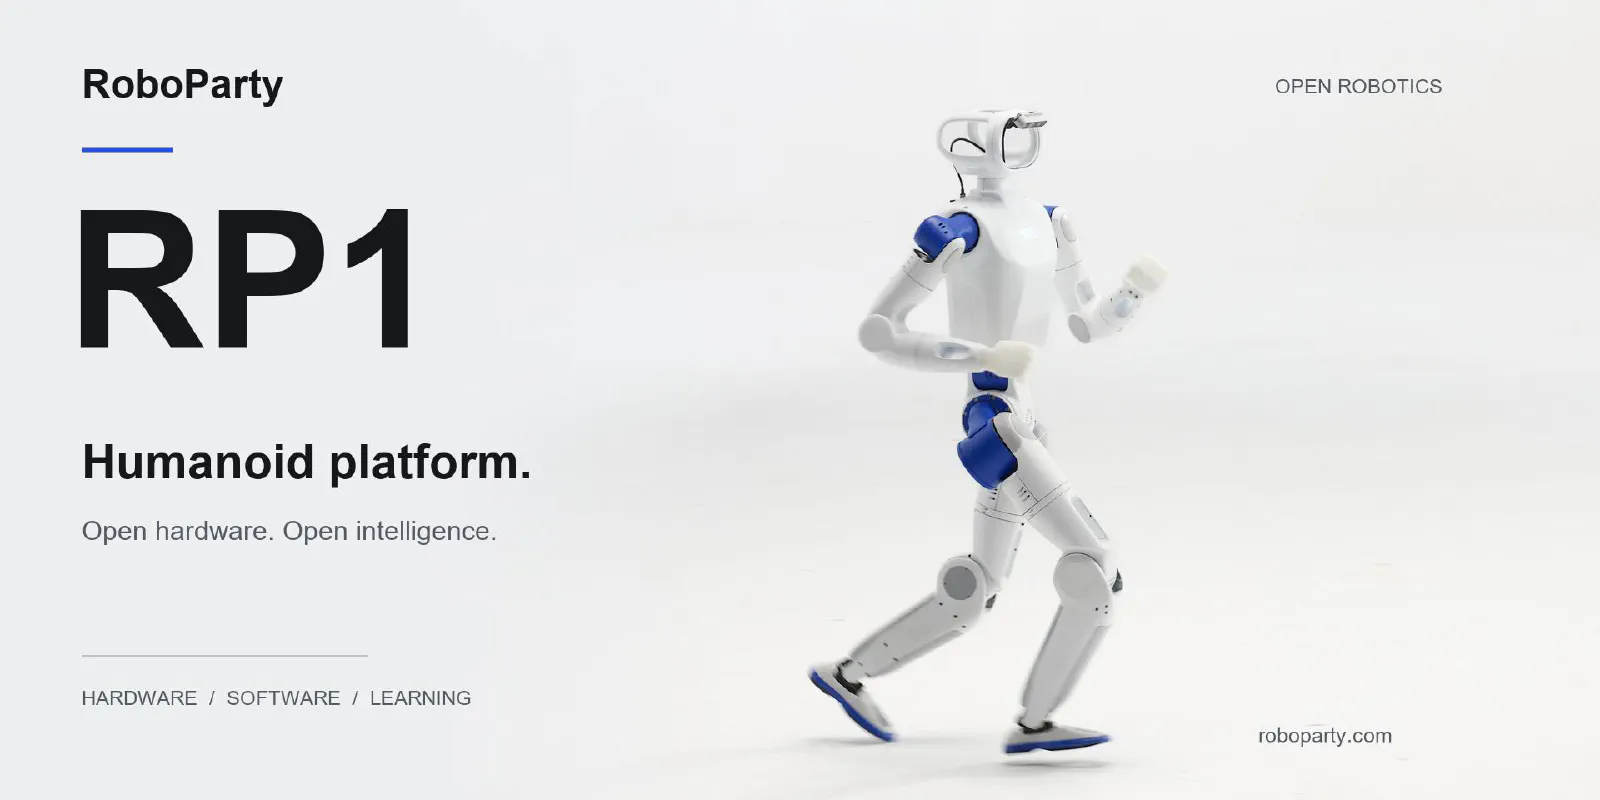
An open-source full-stack humanoid platform spanning mechanical design, electronics, firmware, control, deployment, and learning.
RP1
Recent projects:
An open-source full-stack humanoid platform spanning mechanical design, electronics, firmware, control, deployment, and learning.
luolimasi is now running on Hugo.
Another milestone for RoboParty.
Crazy how time flies.
Everything goes on.
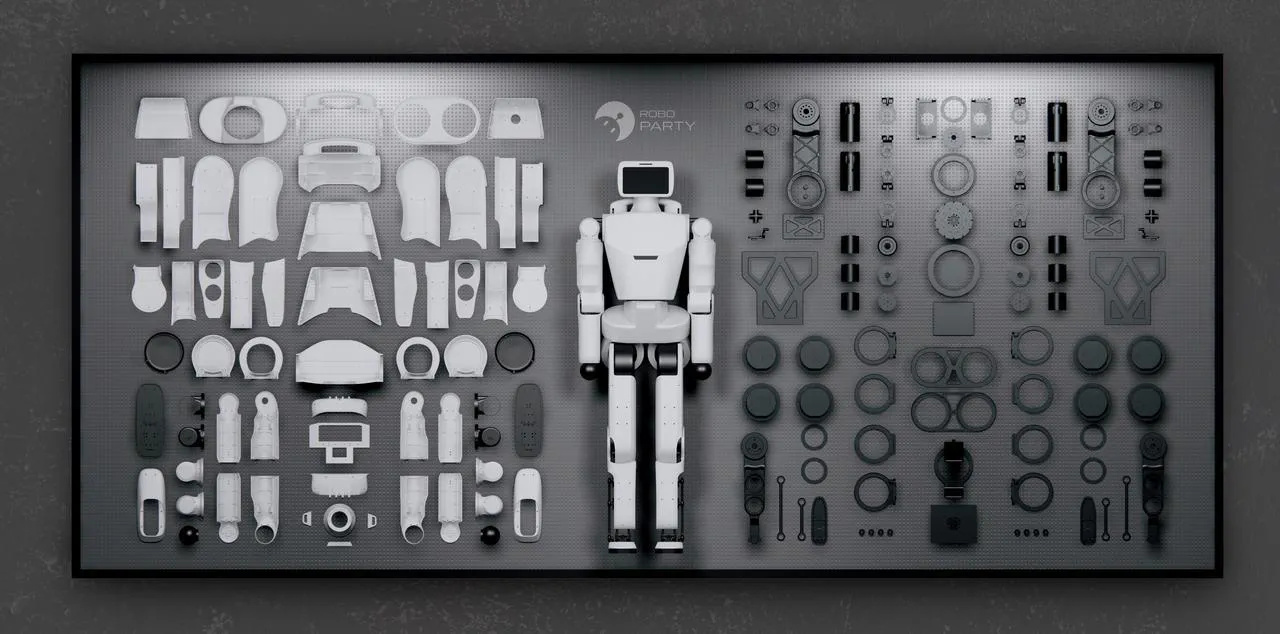
README notes for Roboto Origin, a fully open-source DIY humanoid robot project.
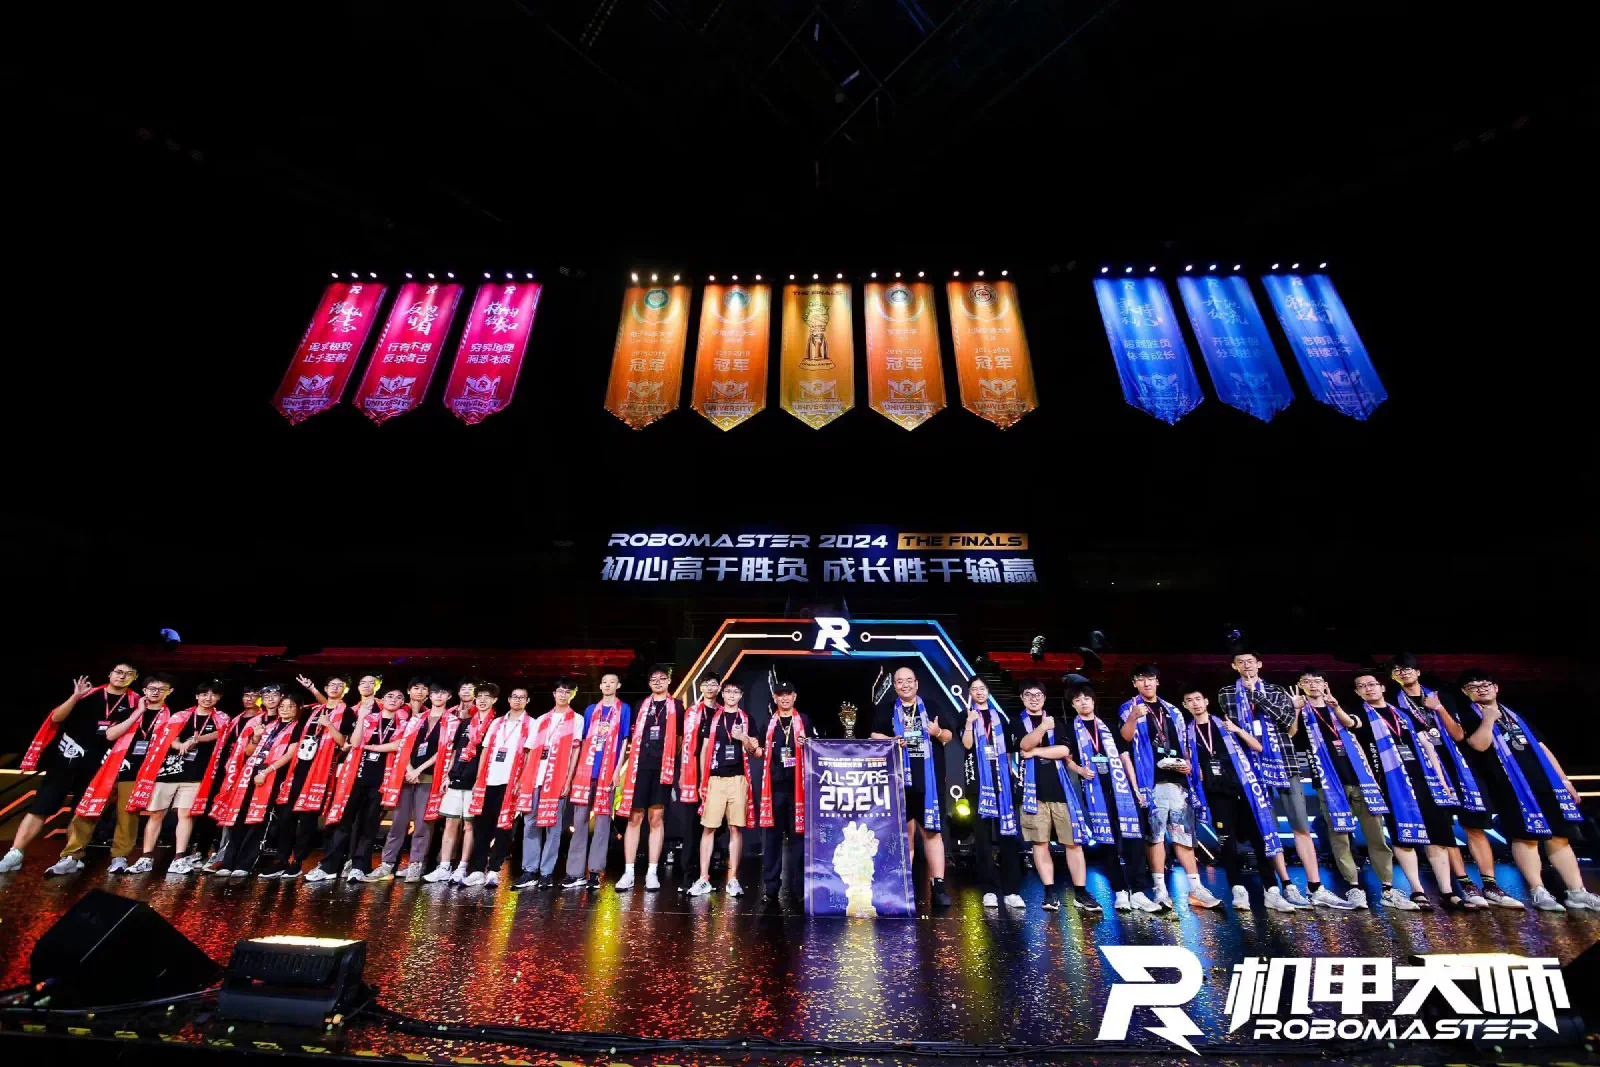
Taking part in the first RoboMaster All-Star Game.
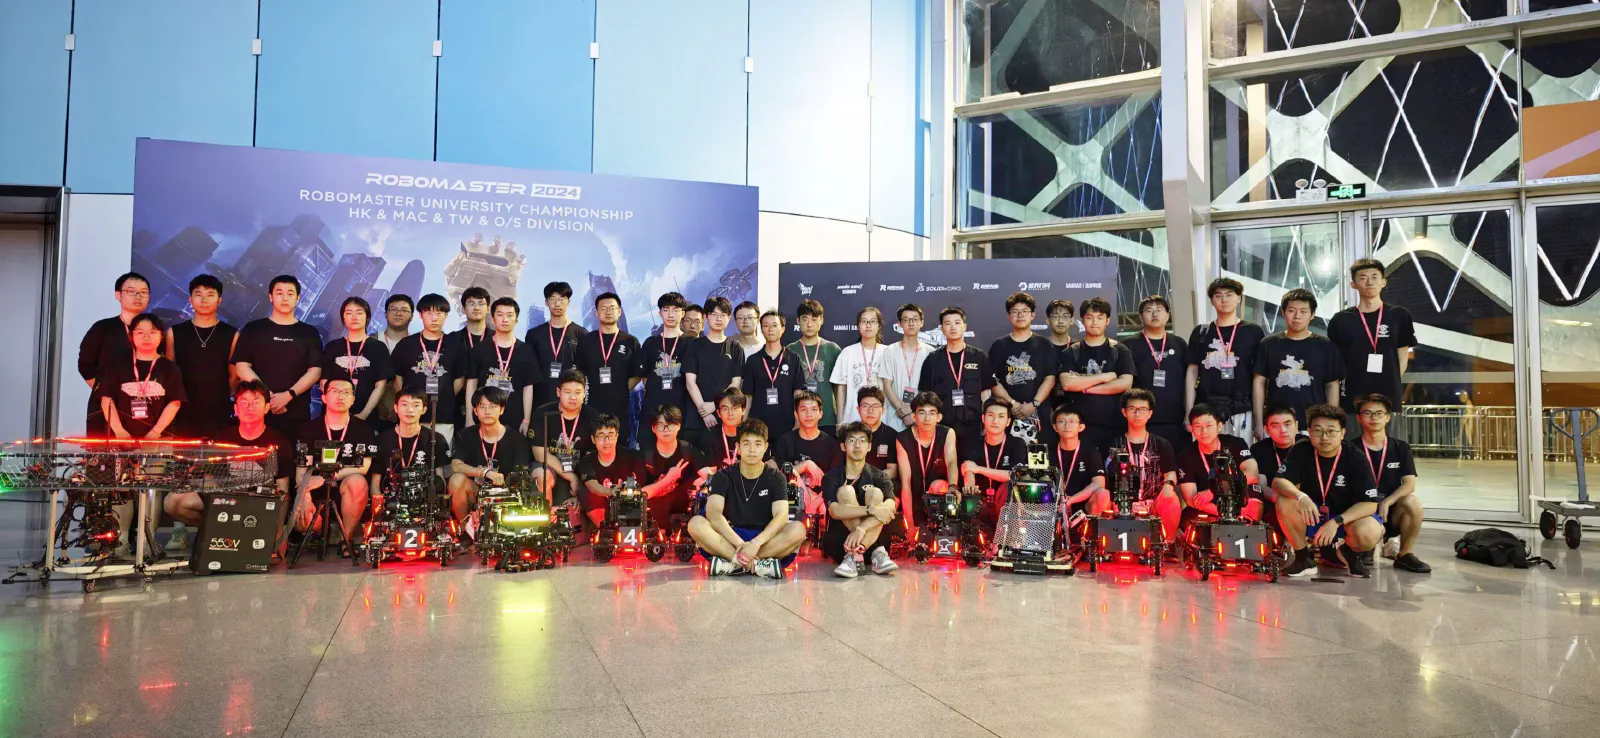
Bad ending.
Looking back on the 2023 RoboMaster season.
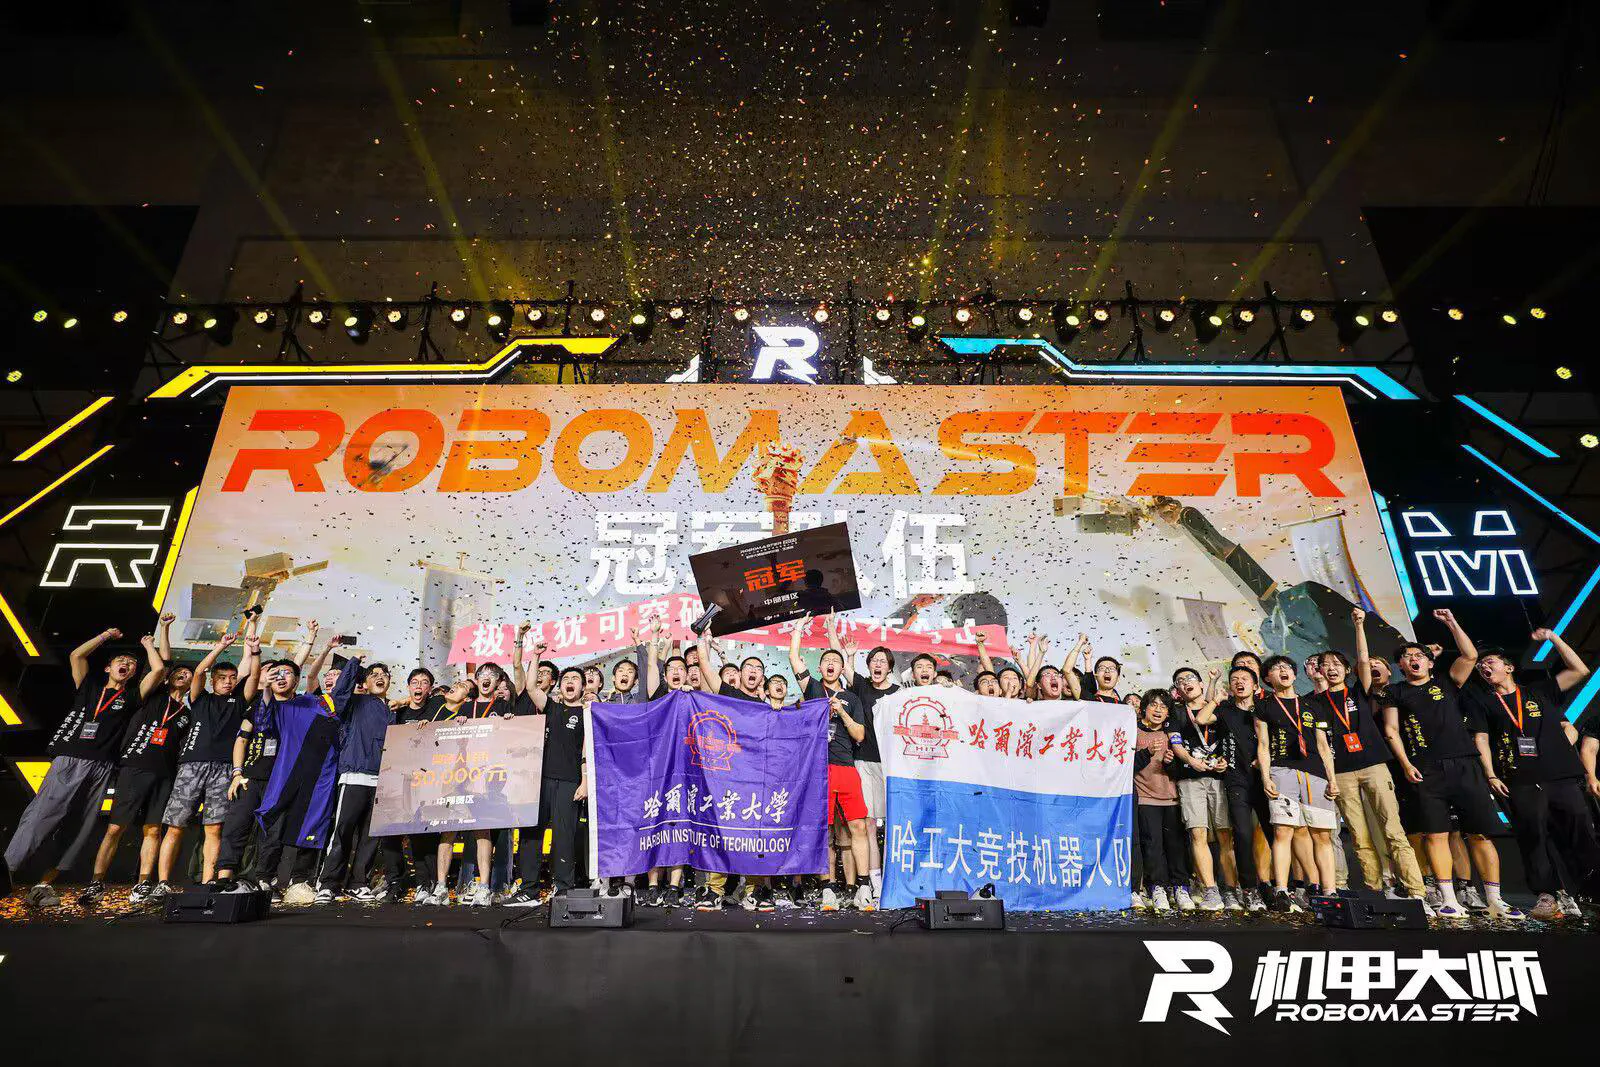
The first championship in I Hiter’s history.